Projects
Ongoing
Current Initiative
W-01
Overview
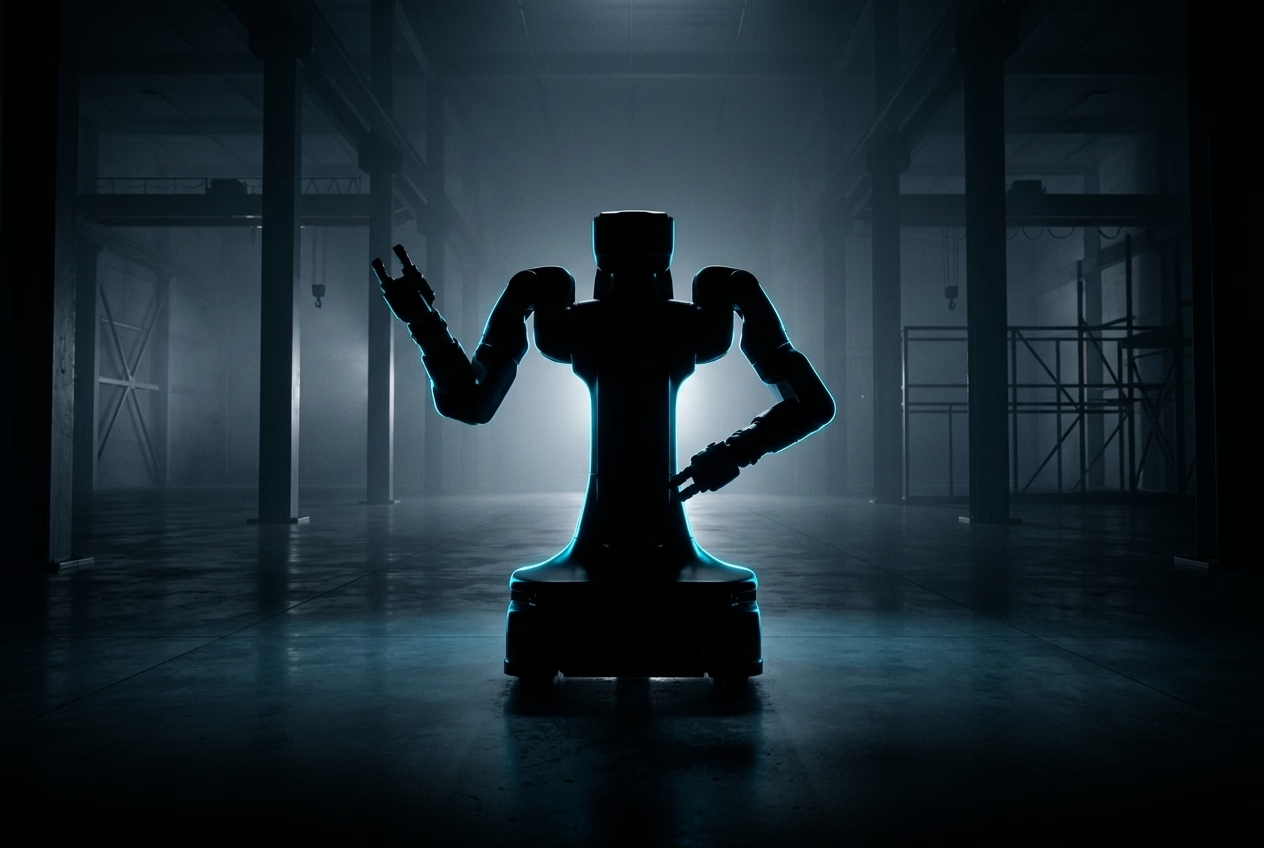
We are developing a revolutionary, general-purpose mobile manipulation platform designed to bridge the gap between digital automation and physical execution. Combining high-mobility locomotion with advanced multi-axis robotic manipulation, our platform is engineered to operate seamlessly alongside human teams in dynamic, unstructured real-world environments.
Timeline
Ideation2024
InceptionQ2 2026
PilotQ1 2027
LaunchQ2 2027
Core Team
TBA
Chief Operating Officer
TBA
Chief Robotics Officer
TBA
Chief Platform Officer
TBA
Founder's Office